A six-legged robot designed and built from scratch, and the main project on this site.
It walks with a custom inverse-kinematics gait, builds a map of its surroundings and
navigates through it, recognises objects, and follows spoken commands.
It also learned to walk by itself. A reinforcement-learning policy trained in Isaac Lab
keeps it walking at full speed after it loses any one of its six legs.
A ROS 2 autonomy stack for an unmanned surface vehicle that inspects and maintains
an offshore wind farm. Our team took first prize in the 2024 challenge organised by Sirehna.
03
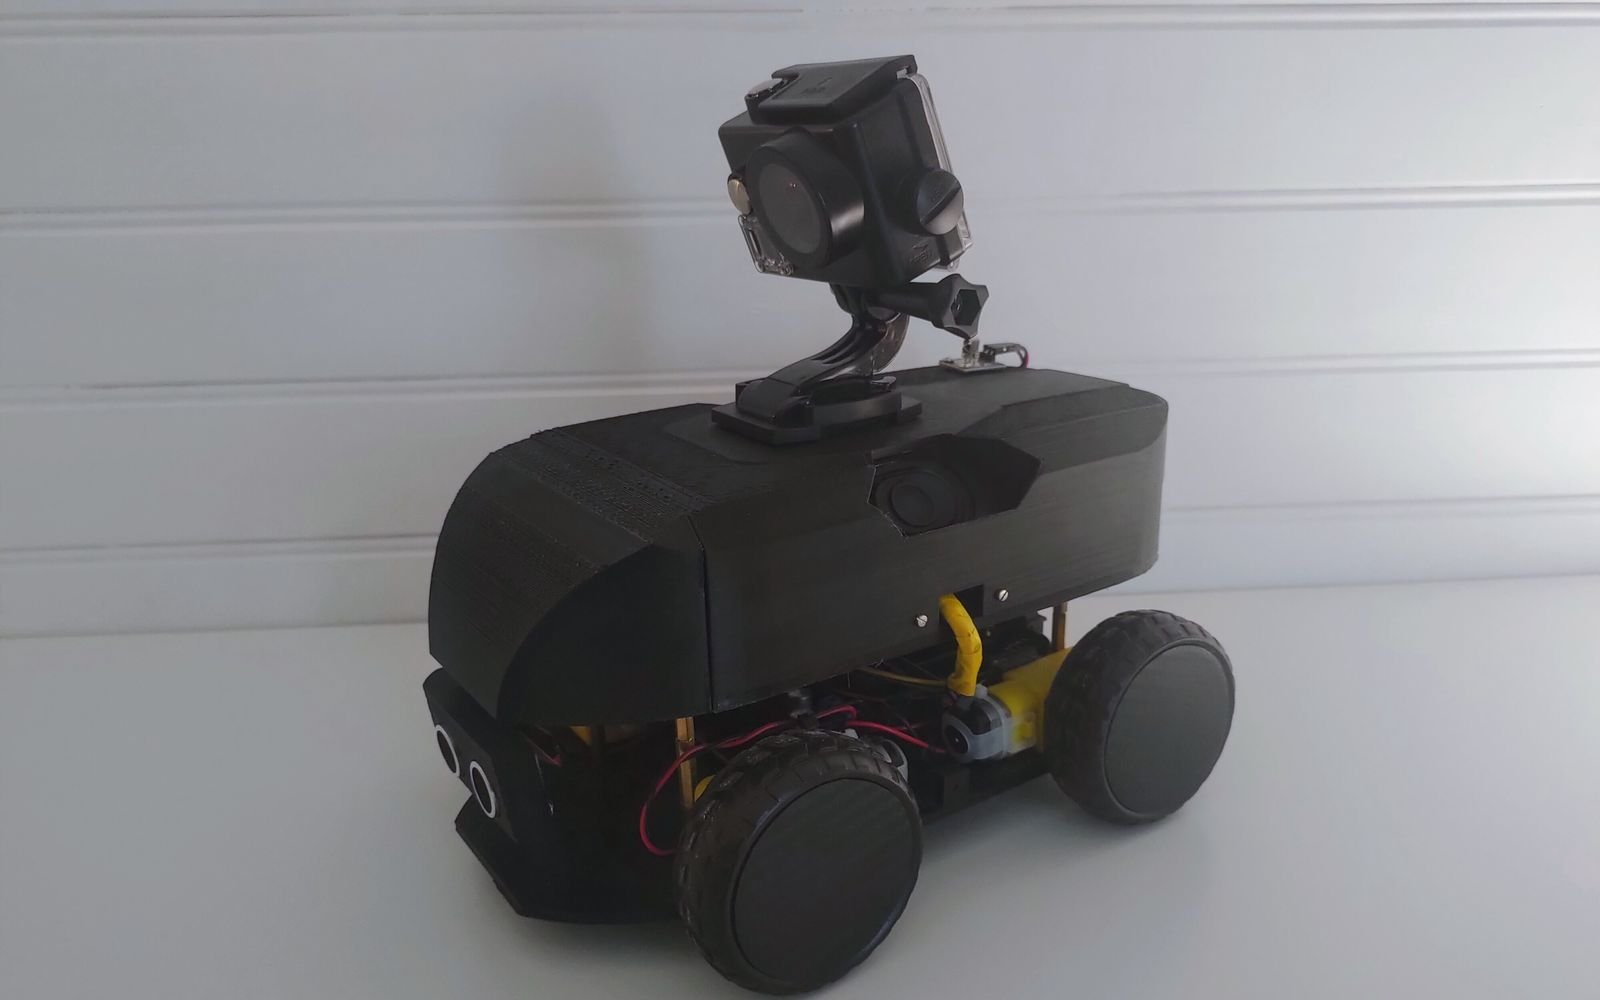
Fig. 03The finished car, with its 3D-printed PETG shell.
A small Arduino robot with a 3D-printed body. It drives until something comes within
40 cm, then swings its ultrasonic sensor left and right on a servo and turns
toward the side with more room. An MP3 module and two speakers, one on each side, let it play sounds.
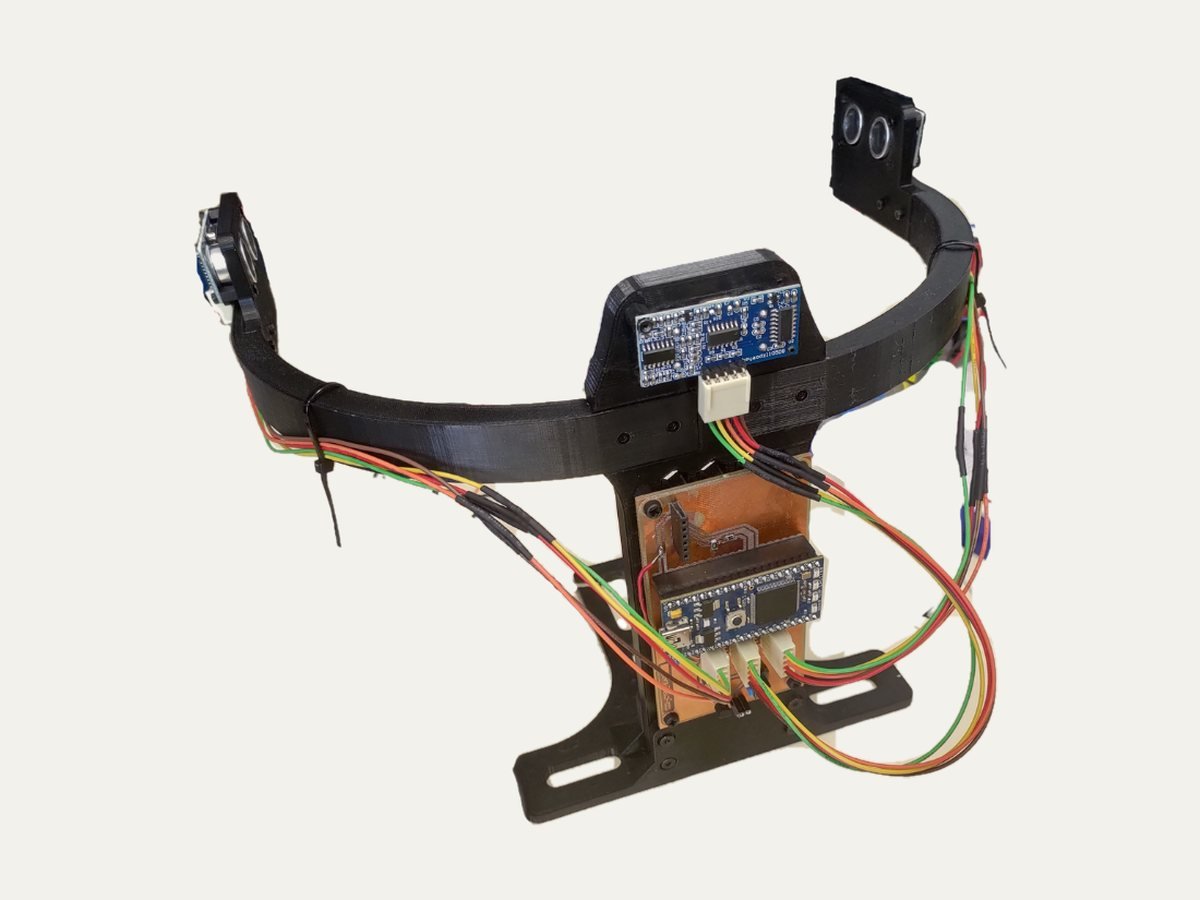
A hands-free controller that lets quadriplegic users drive a robot with their head.
Three ultrasonic sensors around the head measure its position. Tilting to a side turns
the robot, leaning forward drives it, and holding still stops it. An Mbed board on a
custom PCB makes the decision and sends it over Bluetooth.